Ruojing Song Portrait

Ruojing Song (宋若璟)

Student Researcher in Robotics
University of Florida
Latest Updates

🚗 [Opening] I am looking for undergraduate and master's student from CISE, ECE, MAE, ISE departments at University of Florida to collaborate with on my dexterous robotic manipulation project. Welcome to reach out me at !

About Me

Hello! I am Ruojing Song (宋若璟), PhD Student at University of Florida. My research focuses on Dexterous Manipulation and self-evolving physical AI agent.

Specifically, I am interested in systematicaly designing robot learning framework that helps robotic agent to reliably slove complicated task in real world. I am also designing framework that helps robotic agent to constantly evolving in the wild. I believe real wolrd performace is the only evaluation standard for robotic research. Let's work together to deploy reliable robot for manipulation!

Research Thrusts

My primary research interests span 2 key directions in Physical AI:

Dexterous Manipulation

Developing multimodal frameworks that can effectively learn from unstructured human-egocentric dexterous manipulation data, including both highly precise and contact-rich manipulation.

VLA World Model High-precision Manipulation

Self-evolving Physical AI Agent

Building physical AI agent that can constantly improve itself during deployment via effective agentic data pipeline, evaluation system, and contiual learning algorithm.

Reinforcement Learning Continual Learning Self-evoling AI Agent

Publications

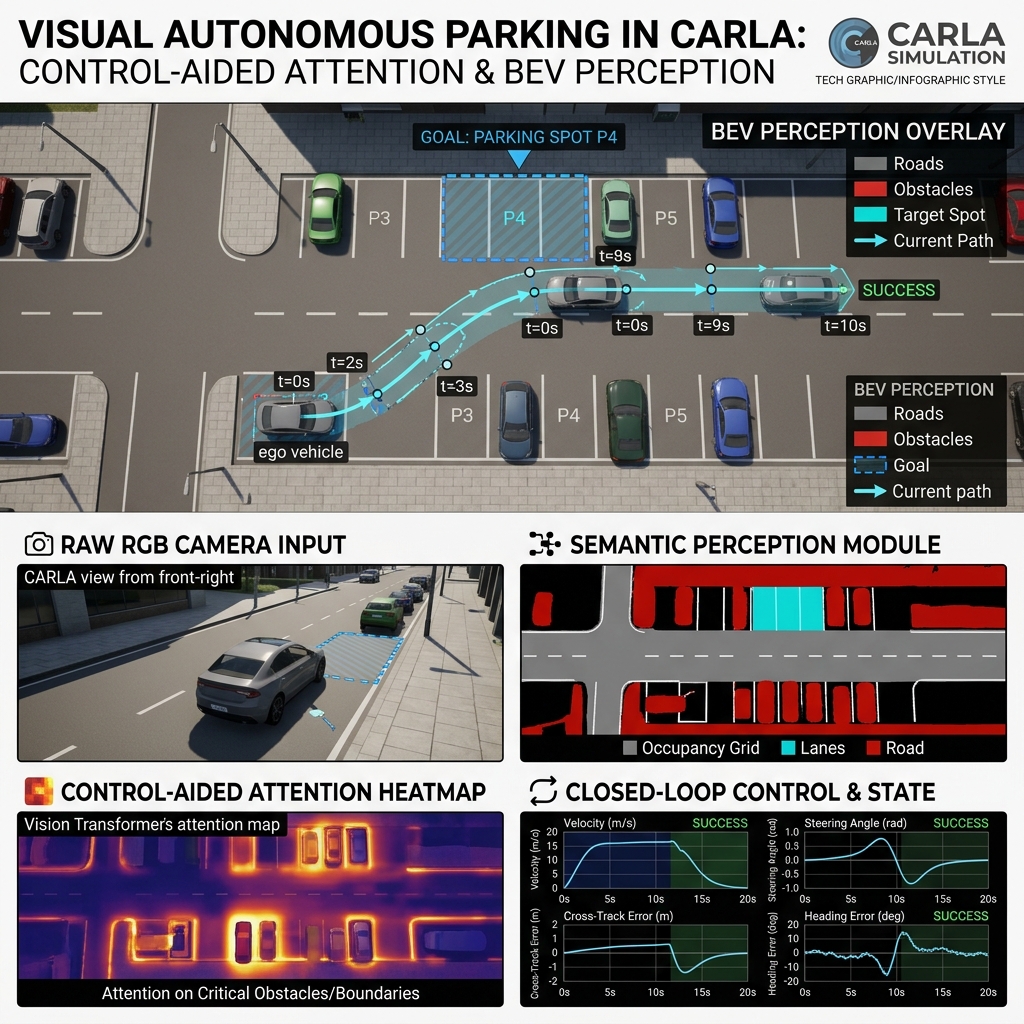
CAA-Policy Teaser
End-to-End Visual Autonomous Parking via Control-Aided Attention
Chao Chen, Shunyu Yao, Yuanwu He, Feng Tao, Ruojing Song, Yuliang Guo, Xinyu Huang, Chenxu Wu, Liu Ren, Chen Feng
arXiv 2025 arXiv preprint arXiv:2509.11090
@article{chen2025end, title={End-to-End Visual Autonomous Parking via Control-Aided Attention}, author={Chen, Chao and Yao, Shunyu and He, Yuanwu and Tao, Feng and Song, Ruojing and Guo, Yuliang and Huang, Xinyu and Wu, Chenxu and Ren, Liu and Feng, Chen}, journal={arXiv preprint arXiv:2509.11090}, year={2025} }
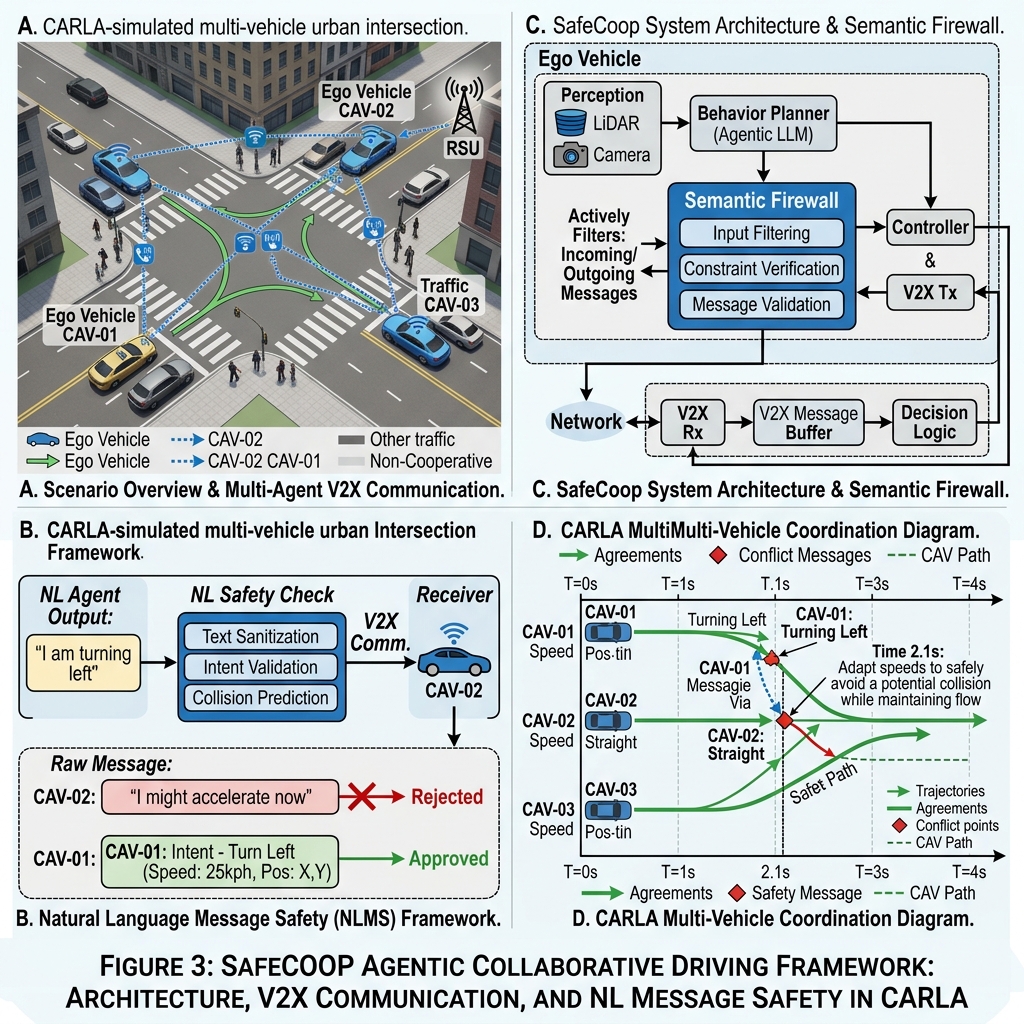
SafeCoop Teaser
SafeCoop: Unravelling Full Stack Safety in Agentic Collaborative Driving
Xiangbo Gao, Tzu-Hsiang Lin, Ruojing Song, Yuheng Wu, Kuan-Ru Huang, Zicheng Jin, Fangzhou Lin, Shinan Liu, Zhengzhong Tu
arXiv 2025 arXiv preprint arXiv:2510.18123
@article{gao2025safecoop, title={SafeCoop: Unravelling Full Stack Safety in Agentic Collaborative Driving}, author={Gao, Xiangbo and Lin, Tzu-Hsiang and Song, Ruojing and Wu, Yuheng and Huang, Kuan-Ru and Jin, Zicheng and Lin, Fangzhou and Liu, Shinan and Tu, Zhengzhong}, journal={arXiv preprint arXiv:2510.18123}, year={2025} }

News & Updates

2025.10
🚀 Our paper SafeCoop: Unravelling Full Stack Safety in Agentic Collaborative Driving is released on arXiv! Check out the Project Page.
2025.09
🚘 Our paper End-to-End Visual Autonomous Parking via Control-Aided Attention is released on arXiv! Code and datasets released at GitHub.